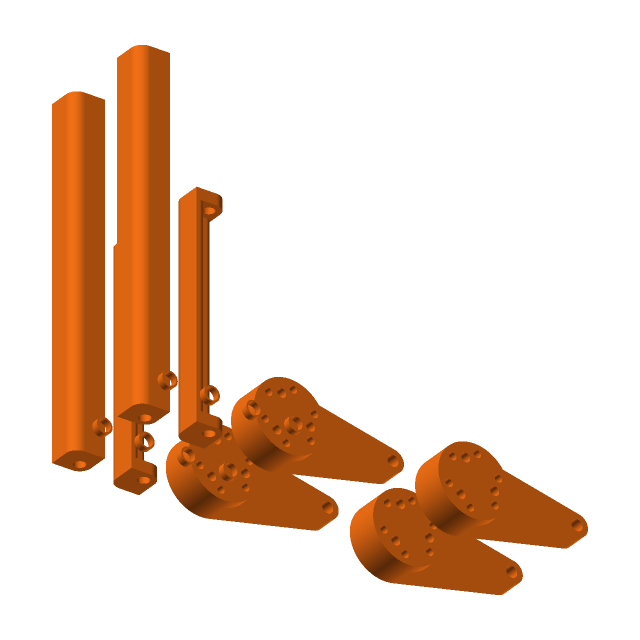Loading…
Open-source humanoid
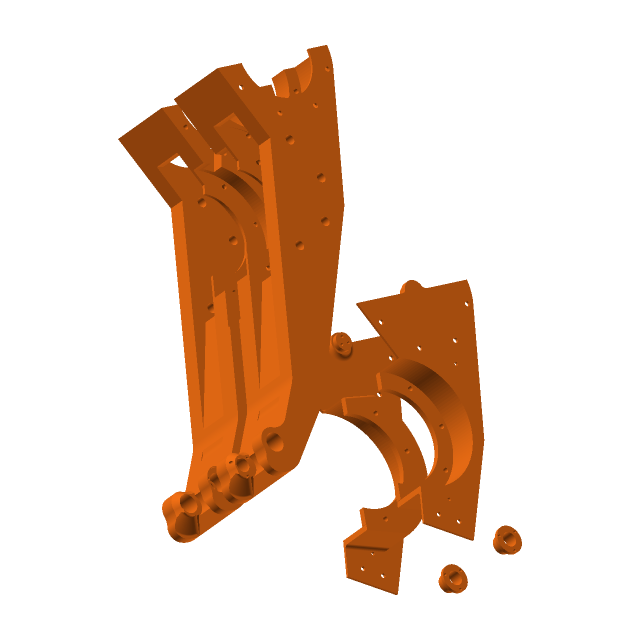
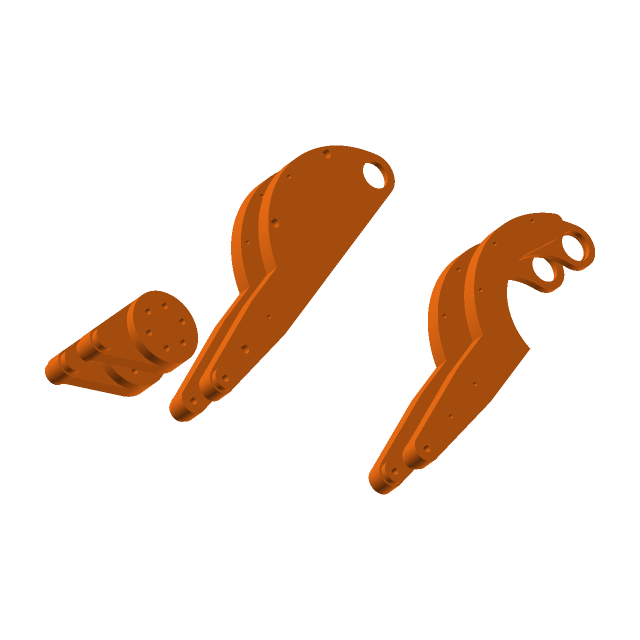
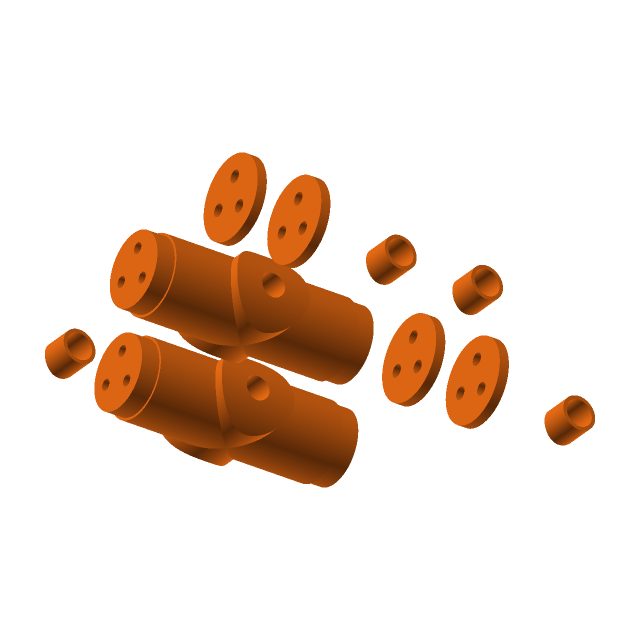
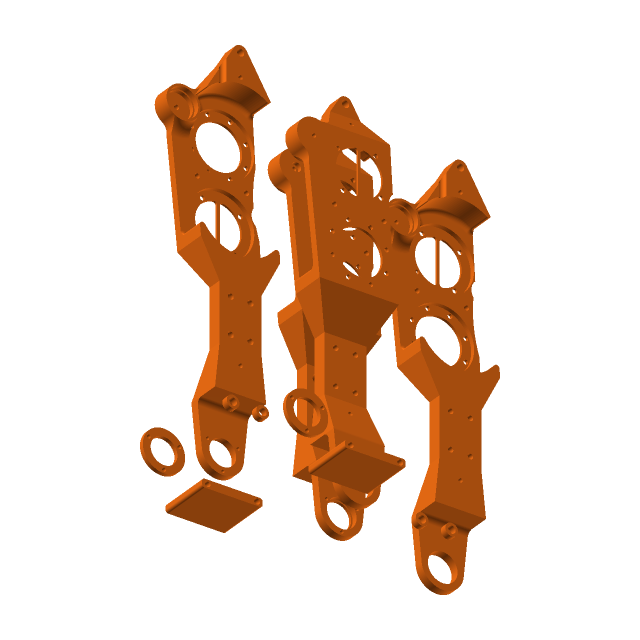
LeRobot humanoid printed parts
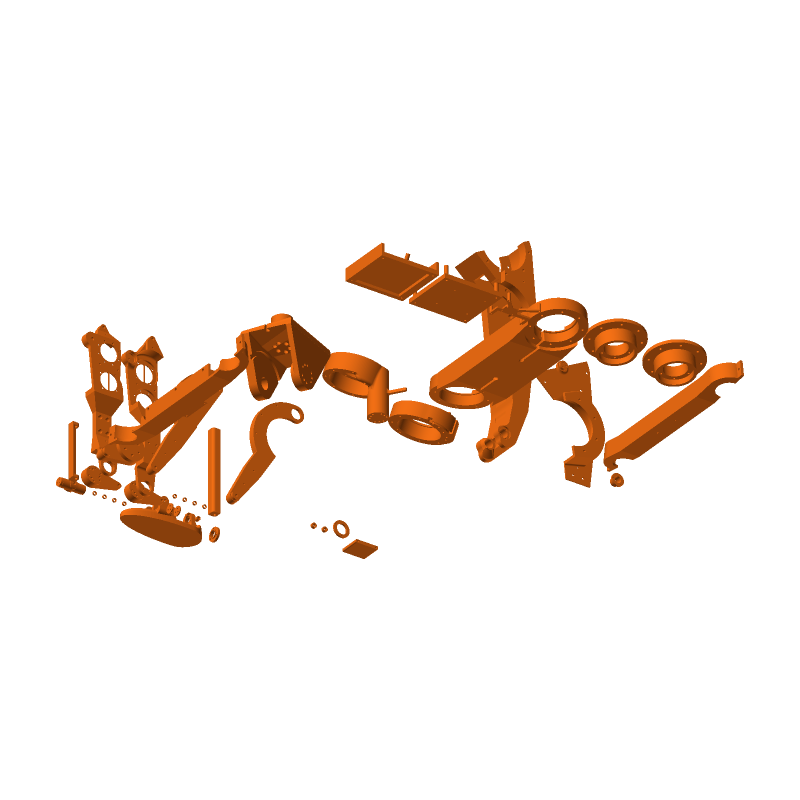
Printed parts for the open-source LeRobot humanoid biped platform — 76 parts across 9 subassemblies, ≈3,817 g of PLA+, printed on enclosed CoreXY machines to the project's printing guide.
Printed to the guide
PLA+, 4 walls, 30–35% (100% for hipx / hipz) infill, gyroid.
Largest part fits
118 × 60 × 391 mm thigh half, printed on its side.
Hardware pack
Fasteners, bearings, electronics and 12 RobStride actuators, kitted per robot.
Build it your way
Full kit, subassembly sets or single spares — left and right.
Subassembly sets
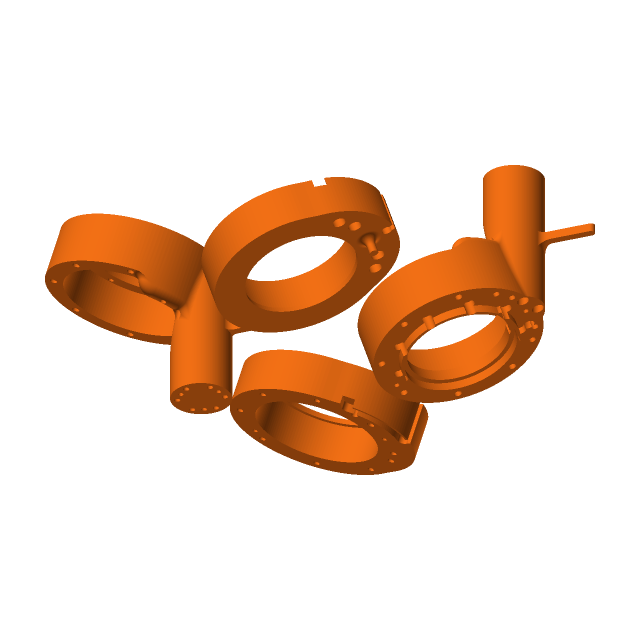
Spares & hardware
Filament by subassembly
| Subassembly | Parts | Filament | Infill |
|---|---|---|---|
| Torso | 8 | 820 g | 30% |
| Hip X (roll) | 2 | 830 g | 100% |
| Hip Z (yaw) | 4 | 650 g | 100% |
| Thigh | 6 | 780 g | 30% |
| Knee mechanism | 6 | 240 g | 30% |
| Shin | 12 | 240 g | 30% |
| Ankle mechanism | 16 | 90 g | 30% |
| Ankle | 10 | 16 g | 30% |
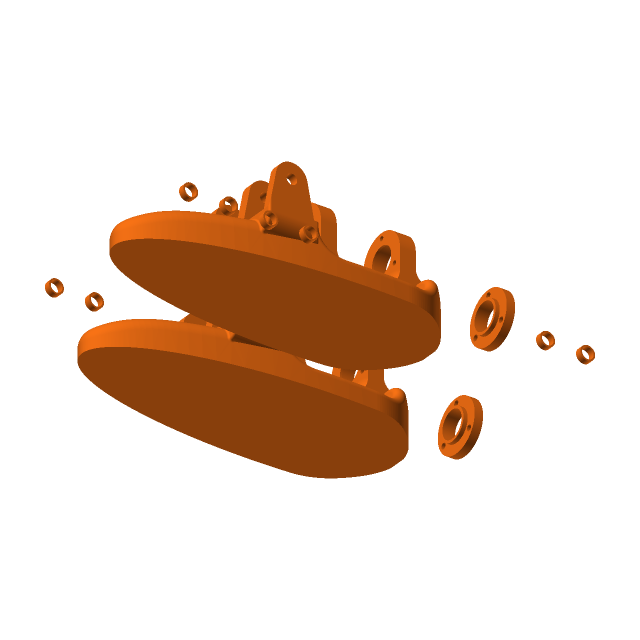
| Foot | 12 | 150 g | 30% |
| Total | 76 |